Zhou Lab
About
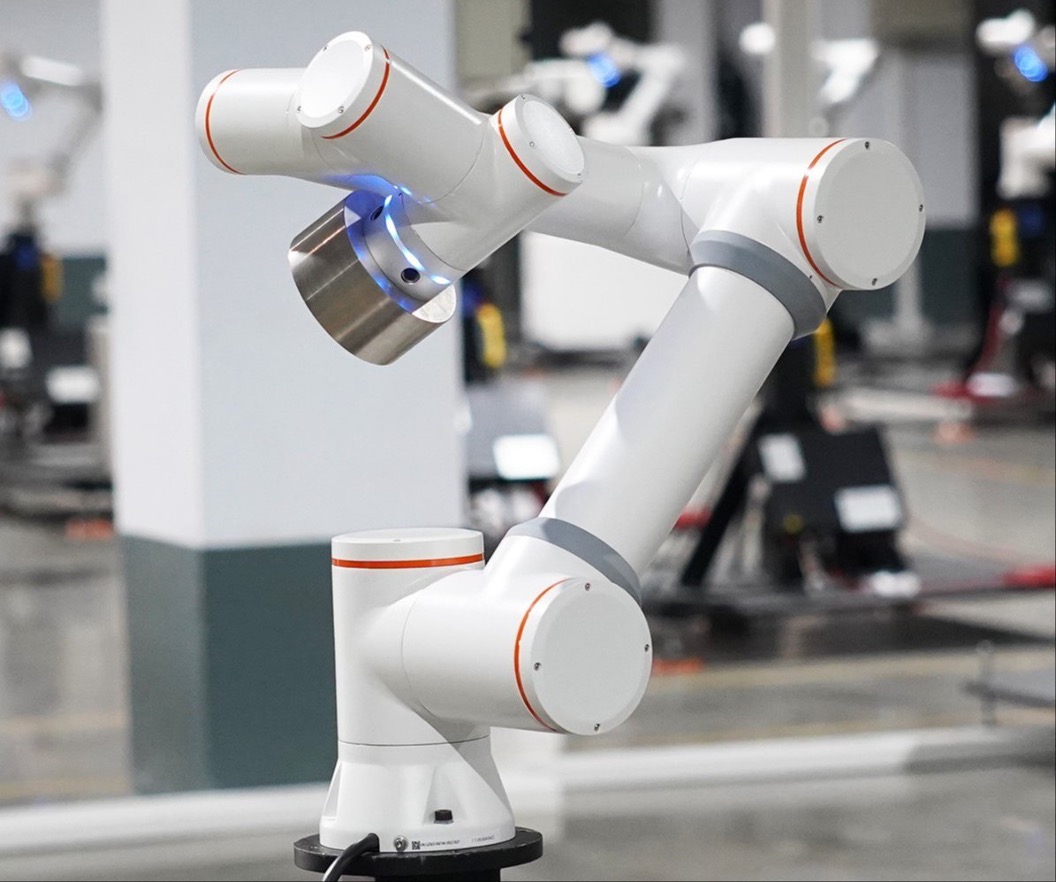
The Drexel Zhou Lab advances the robustness, reliability, and scalability of robotics and multi-robot systems. Our research integrates robotics with foundation models, including LLMs, VLMs, VLAs, and world models, driven by real-world challenges in warehouse logistics, search and rescue, precision agriculture, urban mobility, and agricultural processing.News
| Sep 10, 2026 | Our paper "Vision Language Models Cannot Plan, but Can They Formalize?" won the Best Paper Award at the ECCV 2026 WMEAI Workshop! 🎉 |
|---|---|
| Sep 09, 2026 | Our paper on process-aware robotic food assembly with closed-loop visual monitoring has been published in Journal of Agriculture and Food Research. |
| Sep 05, 2026 | Two papers accepted to SSRR 2026: LLM-based decentralized multi-robot flocking (LLM-Flock) and an interceptor drone for perimeter defense (Project SCOUT). |
| Aug 21, 2026 | Our team placed in the Top-10 of the Multi-Task (Generalist) Track at the RSS 2026 Workshop & Challenge on Post-Training for Robotics Foundation Models. |
| Aug 07, 2026 | Two papers accepted to ECCV 2026 Workshops: aerial-ground cross-view dataset for heterogeneous robot teams (AGT-CV) (CDEL) and VLMs for task formalization (WMEAI). |
| Aug 02, 2026 | Our paper on completion-aware VLA for long-horizon manipulation (SeqVLA) has been accepted to ISRR 2026. |
| Jul 13, 2026 | Two papers accepted to DARS 2026: LLM-driven decentralized swarm foraging and low-cost VLA architecture for soft grasping (VILAS). |
| Jun 16, 2026 | Our paper on identifying planning-critical occluded agents via VLMs has been accepted to IROS 2026. |
| May 27, 2026 | Three papers accepted to CASE 2026: weight-aware robotic grasping via VLA (CLAW), VLA inference optimization for smart agricultural manipulation, and root-oriented geometry for robotic grasping (ROG-Grasp). |
| May 21, 2026 | Our FM-MRS Workshop @ IROS 2026 has been accepted and is now online. |
| May 02, 2026 | Our paper titled "Large Language Models for Multi-Robot Systems: A Survey" has been accepted to Autonomous Robots. |
| Apr 06, 2026 | Our paper titled "Fuzzy Encoding-Decoding to Improve Spiking Q-Learning Performance in Autonomous Driving" has been accepted to NICE 2026. |
| Mar 26, 2026 | Our paper titled "Policy-Guided World Model Planning for Language-Conditioned Visual Navigation" has been accepted to CVPR Workshops 2026. |
| Jan 21, 2026 | Our paper on in-situ microplastic detection on food via hyperspectral imaging has been published in Journal of Chemometrics. |
| Jan 16, 2026 | Our paper on VLA-based intelligent food portioning for small-scale food operations has been published in Journal of Future Foods. |
| Dec 23, 2025 | Two papers published in TASE: failure-aware multi-robot coordination for resilient target tracking and RL for game-theoretic resource allocation on graphs. |
| Dec 19, 2025 | Our paper on spiking architecture for multi-modal decision-making in autonomous vehicles has been accepted as an extended abstract to AAMAS 2026. |
| Sep 29, 2025 | Our paper on hierarchical LLM-in-the-loop optimization for multi-robot tracking under unknown hazards has been accepted to MRS 2025. |
| Jun 15, 2025 | Our paper on resilient multi-robot tracking has been accepted to IROS 2025 and selected as a Best Paper Finalist! |
| May 06, 2025 | Our paper on game-theoretic robot allocation has been accepted to IEEE Transactions on Robotics (TRO). |
| Apr 14, 2025 | Our paper on Finetuning chain-of-thought of small vision-language models for autonomous driving has been accepted to CVPR 2025 WDFM-AD Workshop. |
| Mar 15, 2025 | Our paper on LLM-powered open-vocabulary scene segmentation with language embedded 3D Gaussians won the Best Paper Award at the WACV 2025 LLVM-AD Workshop! 🎉 |
Sponsors
Department of Electrical and Computer Engineering at Drexel University
506 Bossone Research Building, 3140 Market Street, Philadelphia, PA 19104